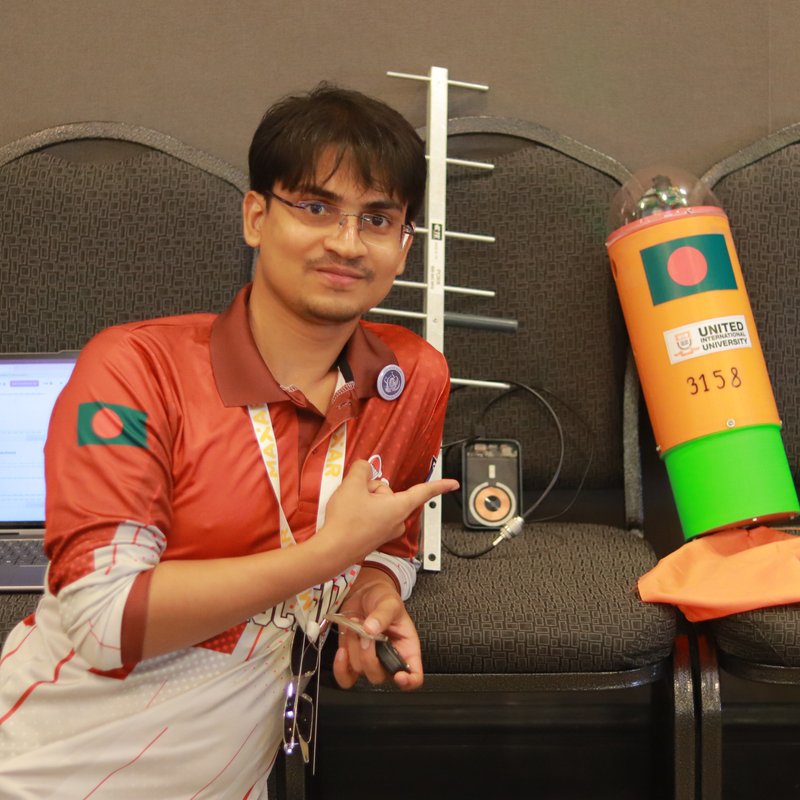
1. AAS CanSat Competition 2025 — 7th Globally (Team Ascend, USA)
2. AAS CanSat Competition 2024 — 11th Globally (Team Astro, USA)
3. BEAR Summit & National Semiconductor Symposium 2025 — ICT Division
4. GSJ Research Paper Publication (2023) — Wireless Sensor Networks in Precision Ag
5. BUP 1st National Research Contest (2022) — Biomass Energy Paper Presentation
6. BUP National Research Project Contest 2.0 (2023) — BUP Research Society
7. IEEE ICDRET Renewable Energy Conference (2021) — IEEE & UIU EEE
8. BUET EEE Day 2024 RoboVerse — Line Following Robot (Team Phoenix)
9. BRACU Traction Omni-Verse — Line Hunter Robotics Segment (ROBU)
10. UIU Innobotics Project Show — Hardware Prototype Showcase
11. UIU CSE Project Show Mentor (Summer 2024) — Dept. of CSE, UIU
12. Japan Job Fair One-Day Intern (2023) — METI Japan & Venturas Ltd.
13. Programming for Everybody (Python) — University of Michigan (Coursera)
14. Cisco Introduction to IoT (2020) — Cisco Networking Academy
15. Cisco Introduction to Cybersecurity (Global VP Copy) — Cisco Academy
16. Cisco Introduction to Cybersecurity (Instructor Copy) — UIU
17. Meta SparkAR Creators' Day (2022) — Meta Developers Circle Dhaka
18. UIU CSE Project Show Volunteer (Spring 2022) — Dept. of CSE, UIU
19. English Olympiad Season-3 — Campus Ambassador Leadership Certificate
20. UNICEF World Water Day Campaign (2021) — UN-Water SDG 6
21. International Virtual Art Summit (2020) — Campus Ambassador